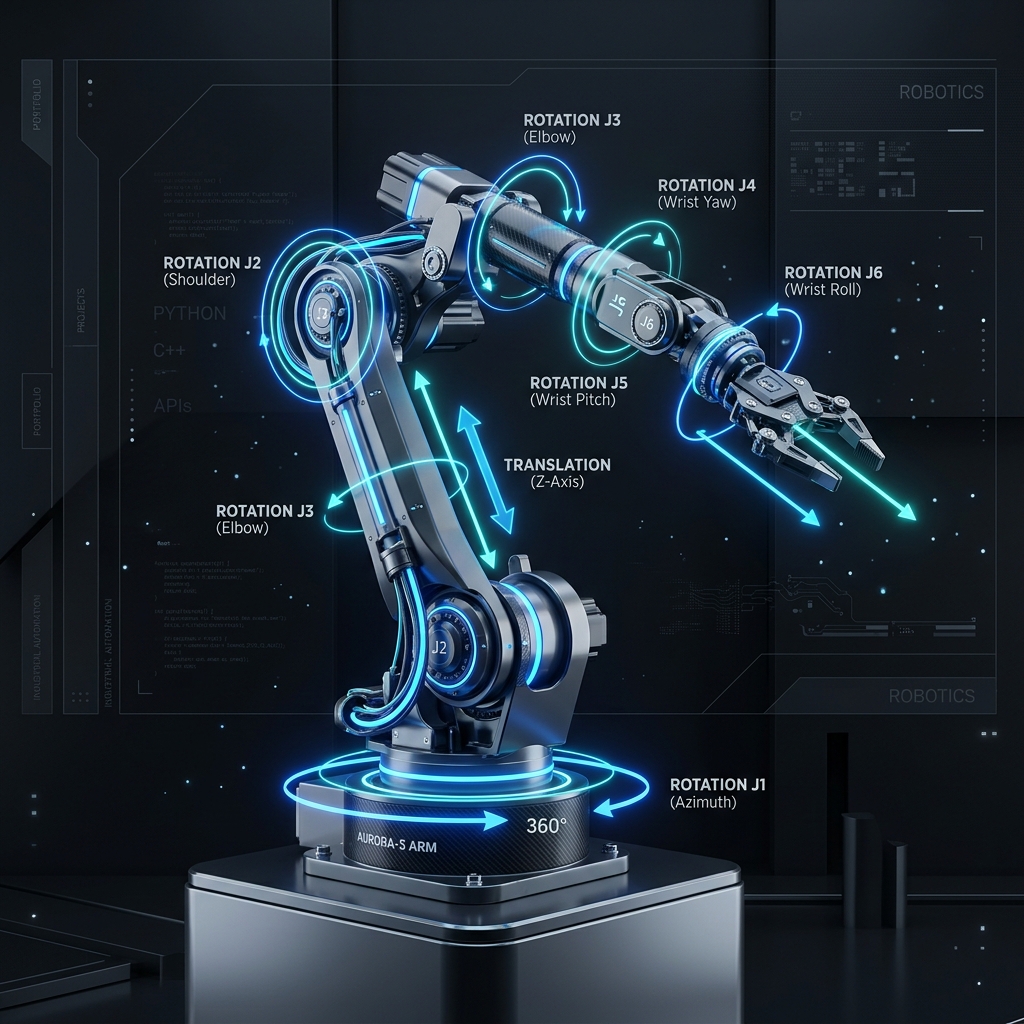
Robotics Manipulator
Implementation of kinematics, dynamics, trajectory planning, and control systems for robotic manipulators using Python and NumPy.
RoboticsControl Systems
# features
Key Features
What the system does.
Kinematics & Transformations
Implementation of spatial descriptions, forward kinematics, and differential kinematics (Jacobians).
Manipulator Dynamics
Analysing system behaviour with rigid-body dynamics and modelling complex multi-degree-of-freedom robotic arms.
Advanced Control Systems
Designing joint space PD controllers, inverse dynamics for task space, and hybrid force/motion controllers.
Computational Robotics
Utilizing the Python scientific stack, including NumPy for matrix operations and Matplotlib for visualizing trajectories.
# simulation
Live Simulation Output
Simulated console execution.
Outputs
Installation & Setup
$_▋
# repositories
Source Code
GitHub repositories for this project.